

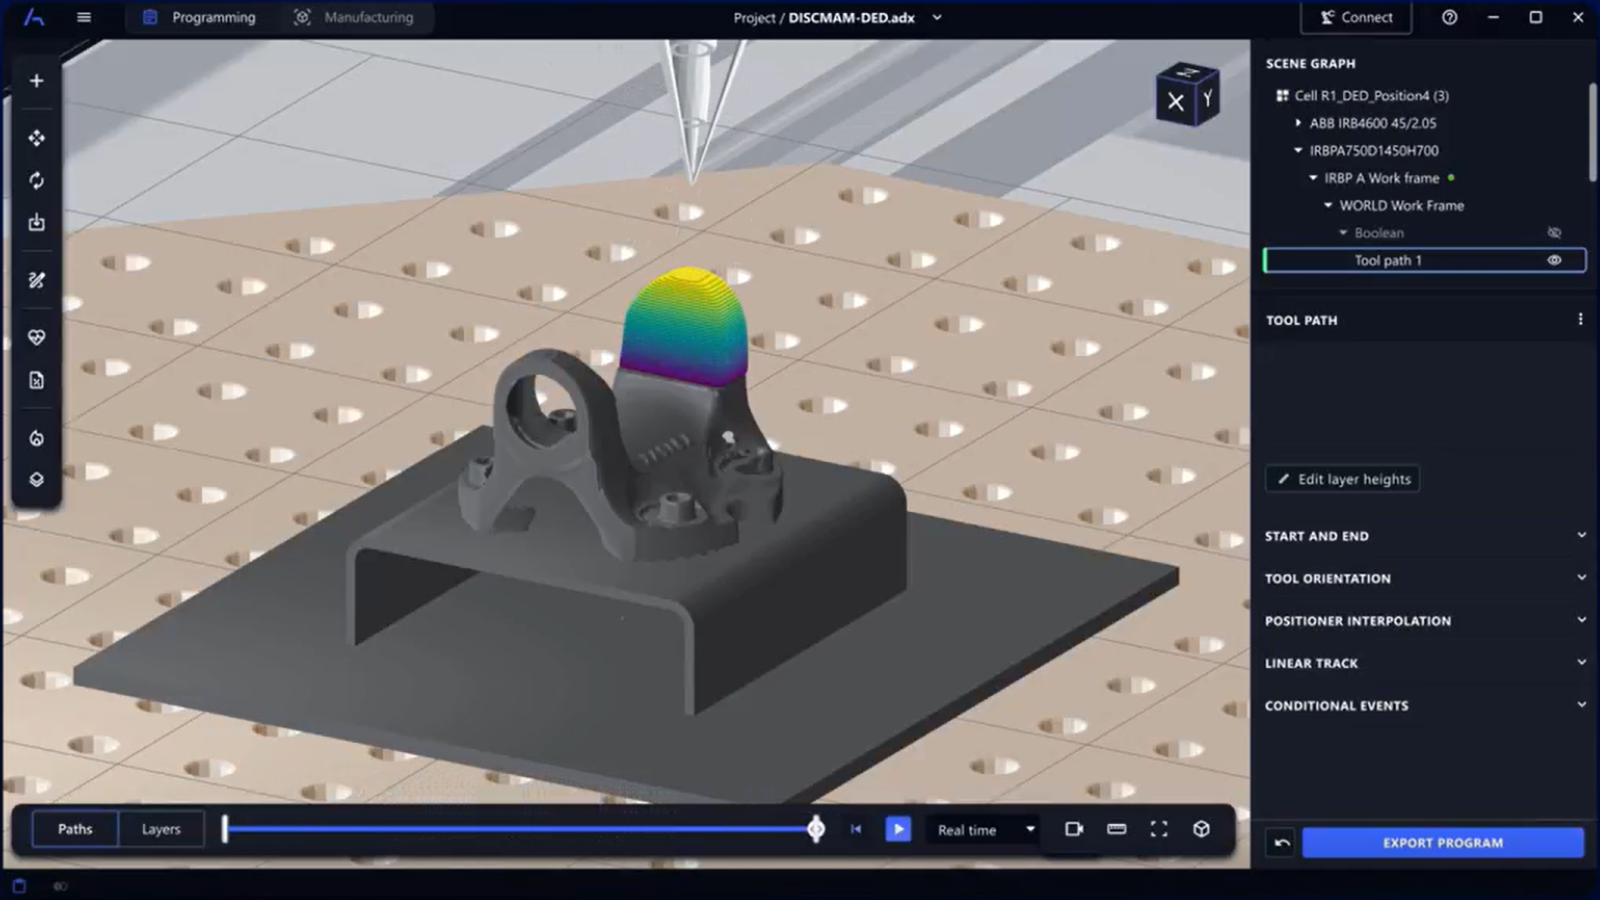
ADAXIS showcases an integrated digital workflow for DED-LB repair during the DISCMAM demonstration
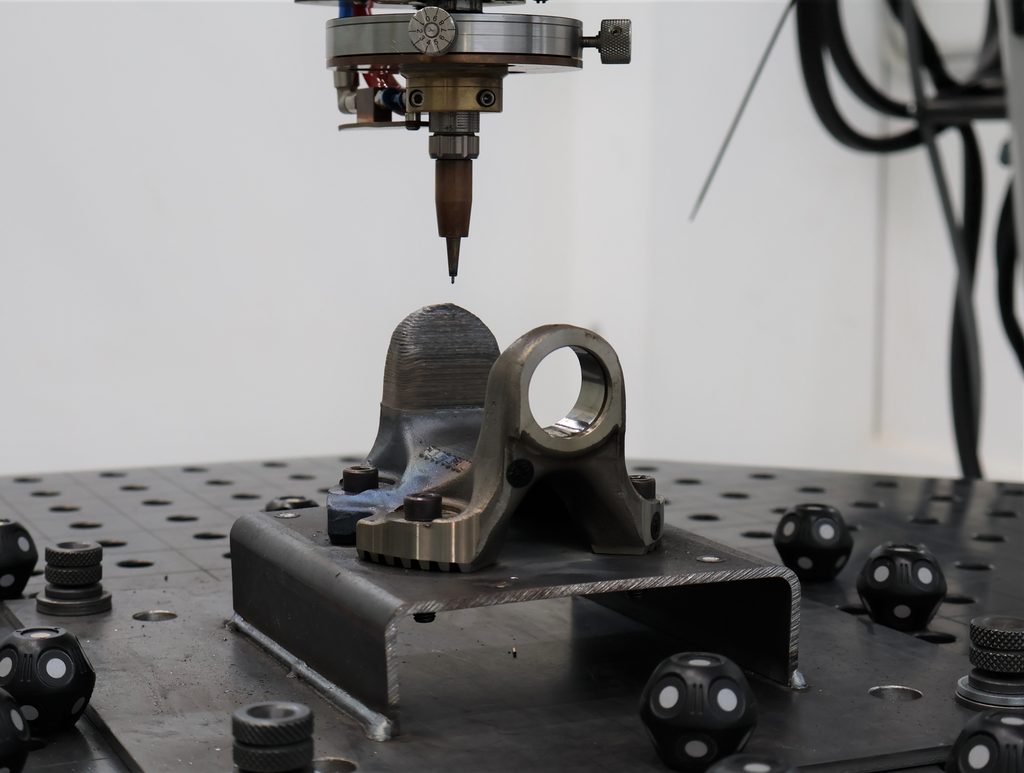
- Through its AdaOne platform, ADAXIS has helped integrate 3D scanning, robotic simulation, DED-LB toolpath generation and real-time process supervision into a continuous digital workflow, demonstrated during the repair of a Unimog joint shaft at LORTEK.
Digitalisation is a key part of the DISCMAM approach to making advanced on-site repair processes more automated, connected and easier to manage. Within the European Defece Fund project, ADAXIS has contributed to this ambition with AdaOne, its software platform for robotic manufacturing and process virtualisation.
We spoke with the ADAXIS team following the demonstration at LORTEK, which focused on the repair of a Unimog joint shaft using DED-LB wire technology and validated the complete digital and manufacturing workflow. In this interview, ADAXIS discusses some of the innovative aspects behind this integrated approach, including the role of the Digital Twin, the connection between virtual planning and physical execution, and how these developments are enabling a continuous digital workflow for advanced on-site repair.
Could you briefly introduce ADAXIS’ role in the DISCMAM demonstration?
ADAXIS is responsible for providing the digital manufacturing environment that enables the preparation, validation, and supervision of the repair process. Through AdaOne, we ensure that all manufacturing operations—including both scanning and additive manufacturing—are properly programmed, simulated, monitored, and executed in a safe and efficient manner.
The demonstration validated the repair of a Unimog joint shaft. How did AdaOne support the complete digital workflow, from 3D scanning and geometry recognition to the final repair operation?
Supporting the digital workflow begins with the scanning operation. AdaOne serves as the central environment for preparing and validating the process, generating and simulating the scanning trajectories while leveraging the combined kinematics of the six-axis robot and the two-axis positioner. This allows the scanning strategy to maximize surface coverage while ensuring safe operation. Through simulation, AdaOne verifies that all required areas are accessible and that the trajectories can be executed without collisions or singularities.
Once the scan data is processed and the repair geometry reconstructed, the resulting model is used in AdaOne as the basis for preparing the additive manufacturing stage. AdaOne generates and simulates the DED-LB repair toolpaths, coordinating the motion of the robot, linear track, and positioner to achieve suitable deposition conditions while maintaining accessibility, process consistency, and safe execution.
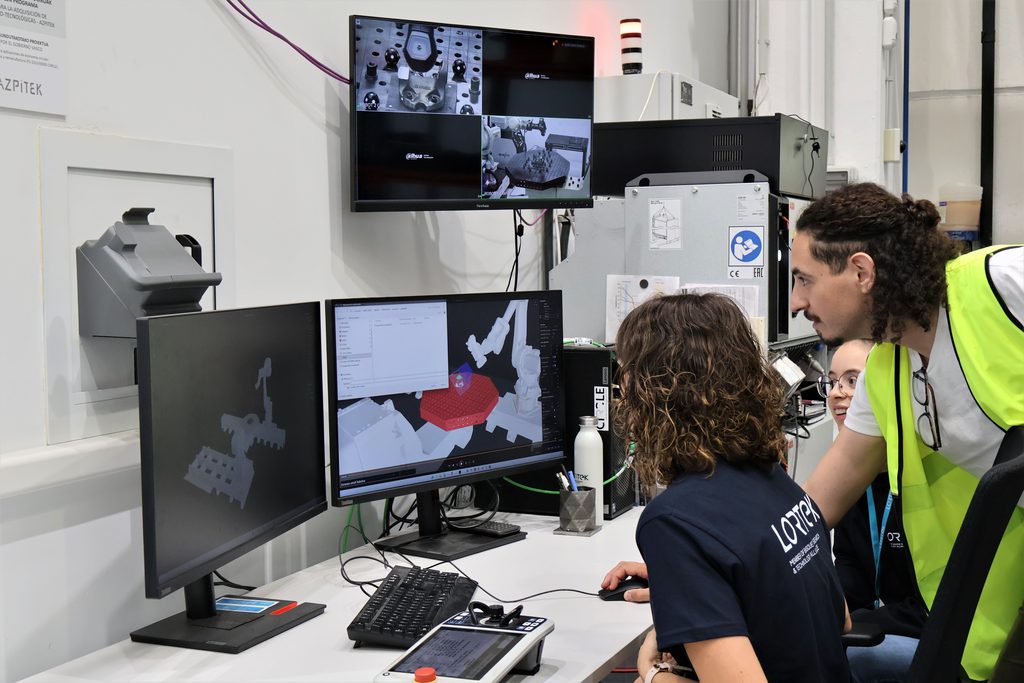
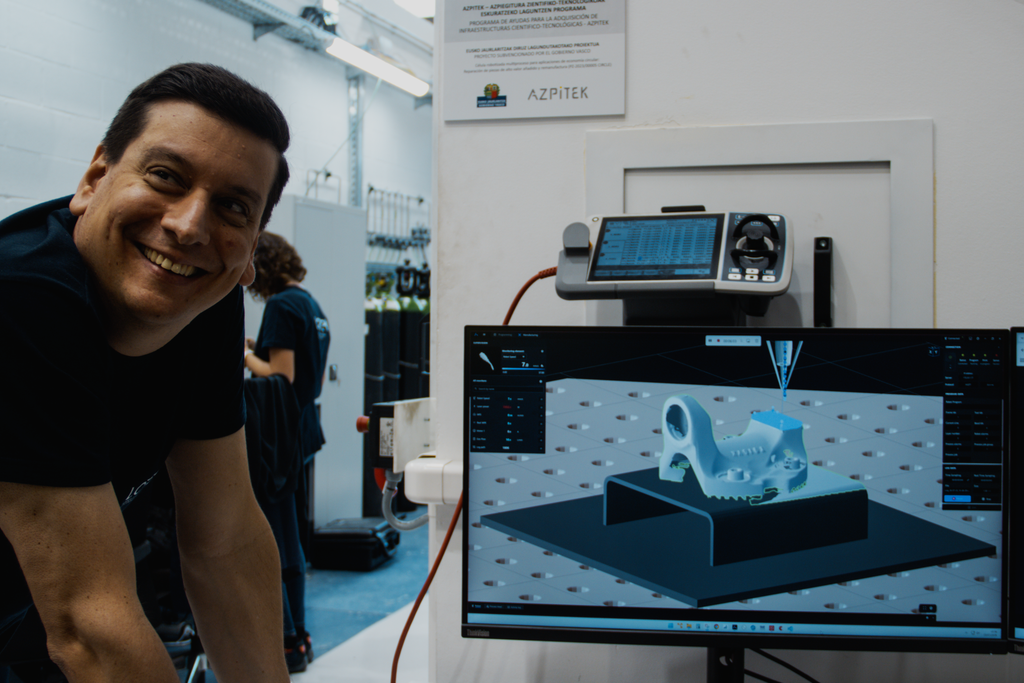
One of the key features demonstrated was the virtualization of the robotic cell together with the 3D scan data. How did this Digital Twin help optimize the repair process before manufacturing began?
The Digital Twin supported the repair process at two complementary levels: offline, as a simulation and planning environment, and online, as a real-time representation of the physical cell.
Before manufacturing, the complete robotic cell, including robots, positioner, tooling, and scanned part geometry, could be simulated in AdaOne. This allowed engineers to develop and validate scanning and repair strategies entirely offline, checking robot trajectories, reachability, collisions, and equipment constraints before executing anything on the real system.
Once the process was running, AdaOne connected the Digital Twin to the physical cell, allowing the virtual environment to reflect the actual robot behaviour and process data in real time. This connection between simulation and reality provided continuous visibility of the operation and helped ensure that the planned repair process was correctly executed on the physical component.
The demonstration combined AdaOne with DISCMAM’s secure digital pathway and LORTEK’s remote monitoring system. From ADAXIS’ perspective, what did this successful integration demonstrate?
From ADAXIS’ perspective, the successful integration demonstrated the feasibility of a complete digital repair chain, seamlessly connecting data acquisition, process planning, manufacturing, and monitoring across multiple systems and stakeholders.
Through AdaOne’s Manufacturing Tab, process data from the cell could be visualized and recorded in real time, enabling both onsite and remote operators to monitor robot behaviour and manufacturing parameters throughout the repair process. This demonstrated how an integrated digital workflow can provide the traceability, visibility, and process control required for distributed repair operations.
What do you consider to be the most innovative aspect of AdaOne’s contribution to the DISCMAM project?
The most innovative aspect of AdaOne’s contribution is its ability to provide a single, continuous digital workflow connecting the physical component, the virtual manufacturing environment, and the real robotic cell.
AdaOne brings together 3D scanning, robotic simulation, automatic multi-axis toolpath generation, and Digital Twin-based process supervision within the same environment. For a highly complex cell combining multiple robots, a linear track, and a positioner, repair trajectories can be automatically generated and validated offline before execution.
Most importantly, this digital workflow does not stop at simulation: once connected to the physical cell, AdaOne enables real-time supervision of the actual manufacturing process through the same Digital Twin. This continuity between offline planning and online execution is, from our perspective, one of the key innovations demonstrated by the project.
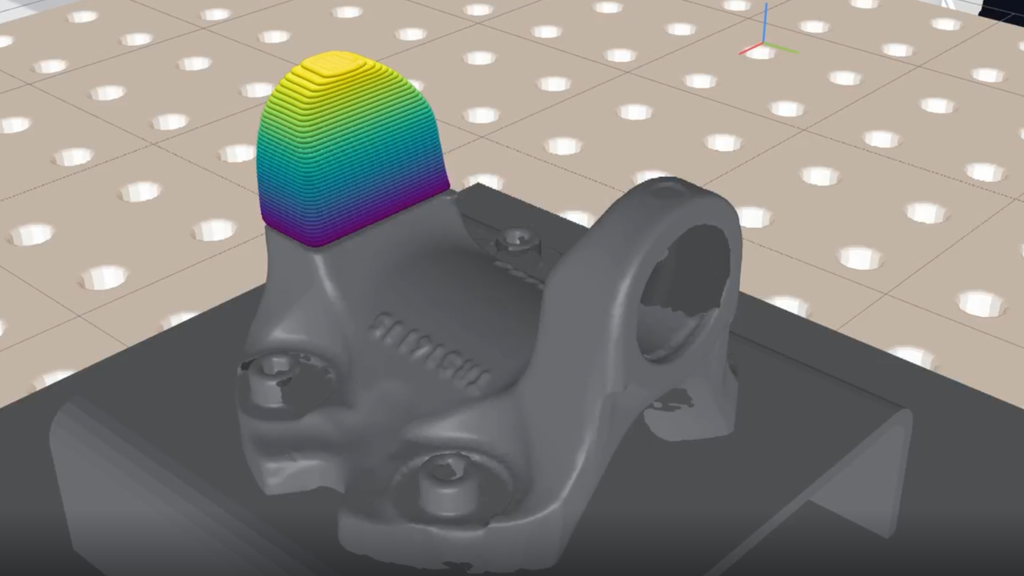
Check out this video showcasing the complete workflow powered by ADAXIS’ AdaOne platform within DISCMAM.


